Robotics & physical AI
Gemini Robotics 2.5
Google DeepMind
The models are intended to interpret a robot's surroundings and support compatible robot tasks.
Search published AI tools, models, robots, and research. Filter by organization, geography, milestones, and evidence.
Robotics & physical AI
Google DeepMind
The models are intended to interpret a robot's surroundings and support compatible robot tasks.
Robotics & physical AI
NEURA Robotics
A humanoid platform NEURA presents for development and industrial training, with multiple distinct hardware generations.
Robotics & physical AI
Shenzhen Dobot (DOBOT)
LUMO is a humanoid robotics platform whose proposed applications include interaction and service tasks.
Robotics & physical AI
AiMOGA Robotics (Chery Group)
The developer describes Mobo as combining speech and vision for interaction in the home.
Robotics & physical AI
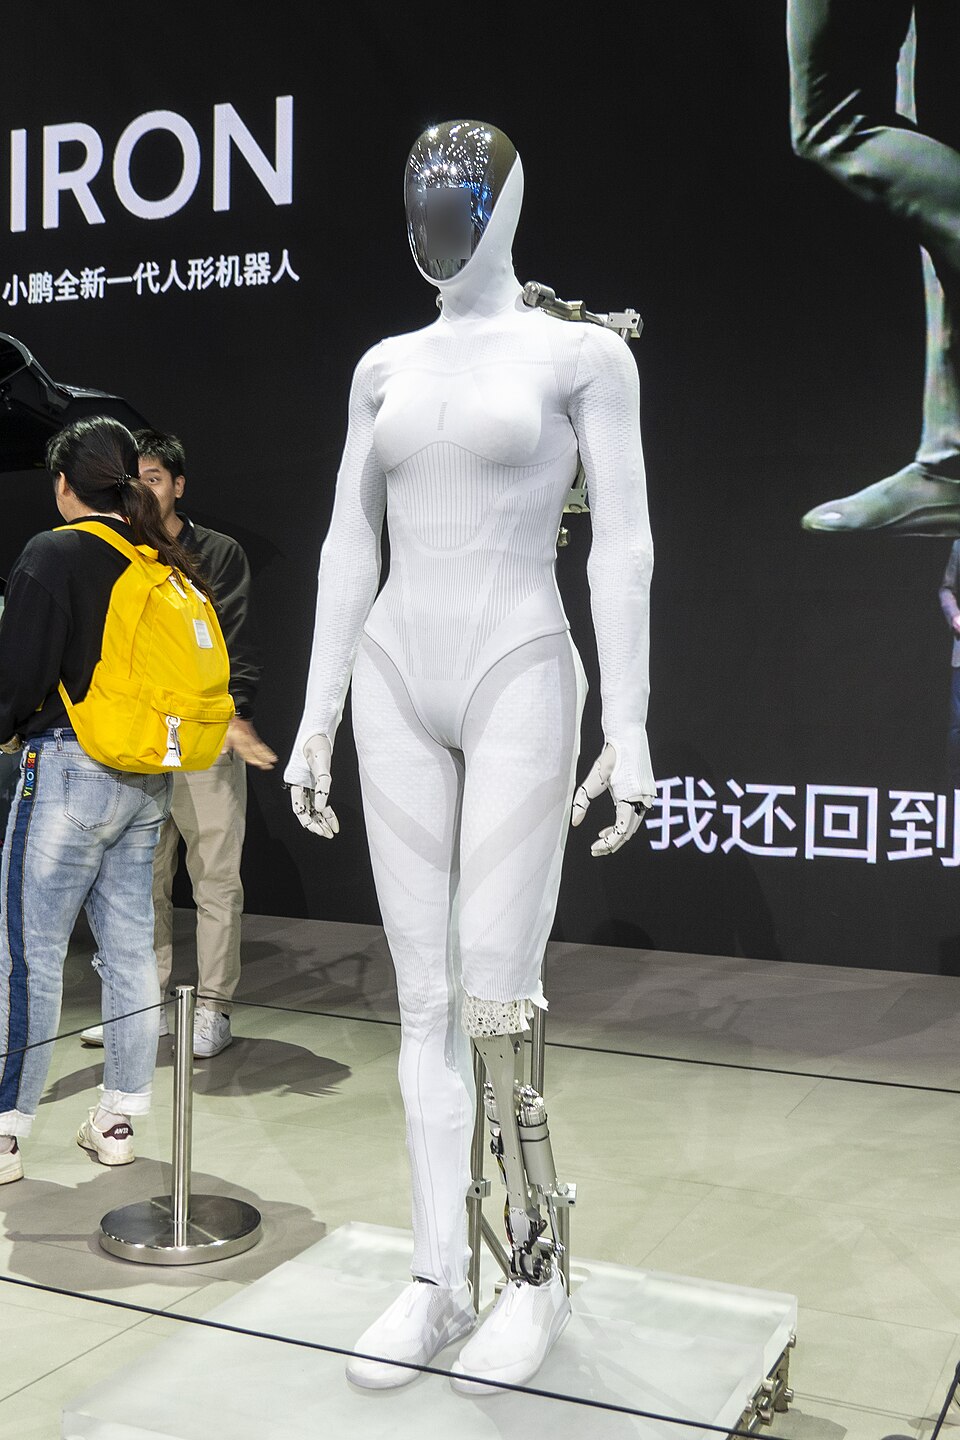
XPENG
A general-purpose humanoid developed for physical tasks with XPENG’s onboard AI systems.
Robotics & physical AI
Addverb (Reliance)
A wheeled humanoid platform designed to help with tasks in warehouses and factories.
Robotics & physical AI
UBTECH Robotics
Uses a battery-swapping mechanism and task-planning software for industrial work.
Robotics & physical AI
1X Technologies
NEO is a humanoid robot designed for documented home-assistance tasks.
Robotics & physical AI
Unitree Robotics
Provides a humanoid platform with onboard compute for development and research.
Robotics & physical AI
Figure AI
Pairs the Figure 03 humanoid hardware with the developer’s Helix vision-language-action model.
Robotics & physical AI
Fourier
Provides a soft-covered humanoid platform designed to interact with people through multiple modes of communication.
Robotics & physical AI
NVIDIA
An NVIDIA research model for humanoid robots that combines visual and language inputs to study manipulation across different robot configurations.
Robotics & physical AI
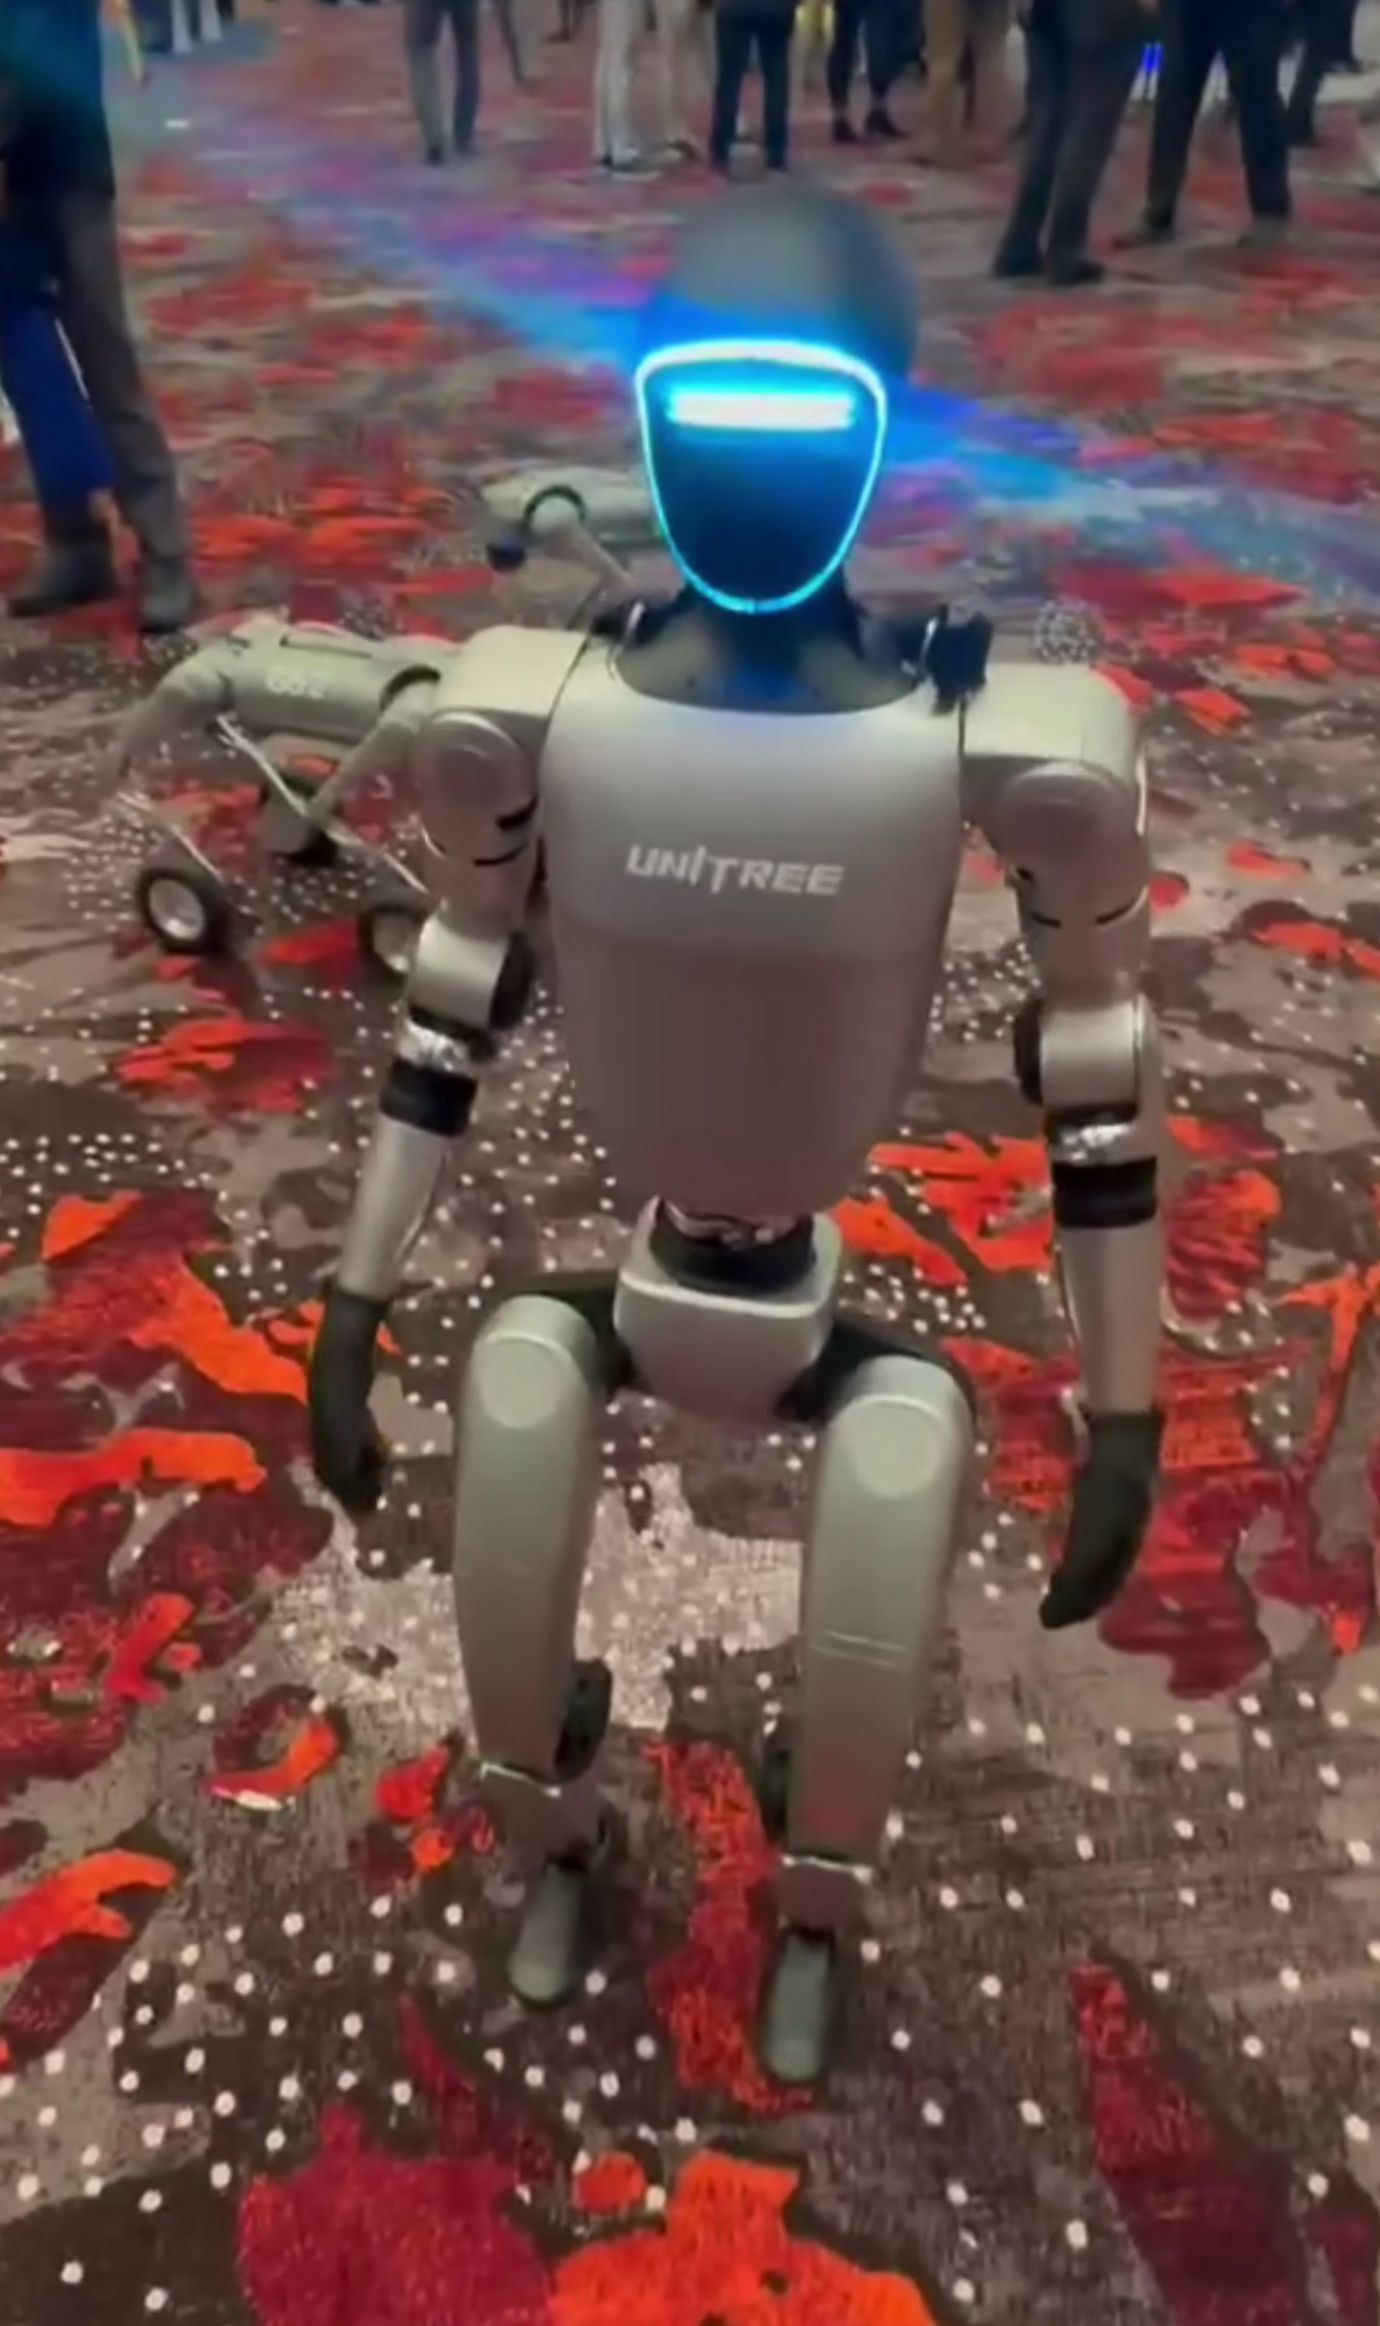
Unitree Robotics
Its official specifications describe a bipedal robot with articulated joints and options for development.
Robotics & physical AI
Boston Dynamics (Hyundai Motor Group)
It is a bipedal robotics platform designed to move and manipulate objects.
Robotics & physical AI
Rainbow Robotics
Combines a mobile base and two manipulators for robotics research and application development.
Robotics & physical AI
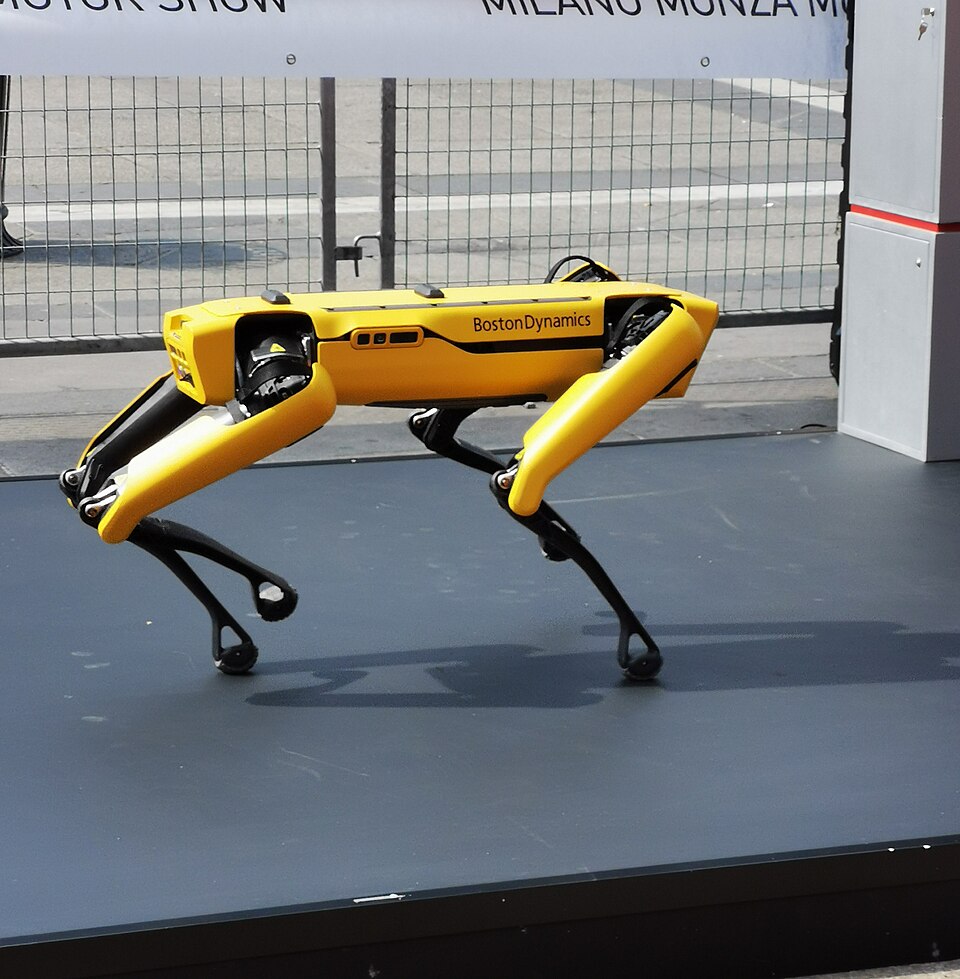
Boston Dynamics
Carries inspection sensors along repeatable routes and traverses stairs and uneven ground to gather site data.
Robotics & physical AI
Hugging Face
A PyTorch toolkit for robot learning that supplies models, datasets and tools for researchers working with physical robots.
Robotics & physical AI
Genesis-Embodied-AI (academic consortium)
A physics simulator designed for robotics and embodied AI research, with support for different types of simulated physical systems.
Robotics & physical AI
Hugging Face
A compact vision-language-action research model that uses visual inputs and instructions to study robot manipulation with shared LeRobot data.
Robotics & physical AI
Unitree Robotics
A Unitree research model that combines a learned representation of a robot’s surroundings with prediction of actions for manipulation tasks.
Robotics & physical AI
AgiBot
An AgiBot World vision-language-action model designed to study robot manipulation from visual observations and instructions.
Robotics & physical AI
Tsinghua University
A research model based on a diffusion transformer that uses images and language instructions to study two-handed robot manipulation.
Robotics & physical AI
Stanford University et al.
A research model that uses camera images and instructions as input for robot actions and was trained on data from multiple robot types.
Robotics & physical AI
Agility Robotics
Transfers totes in warehouse workflows and is managed through the Agility Arc fleet system.


